AMC2 27.801(e) and
27.802(c) Model test method for flotation stability
ED
Decision 2023/001/R
This AMC should be used when showing compliance with CS 27.801(e) or CS 27.802(c) as introduced at
Amendment 5.
(a) Explanation
(1) Model test
objectives
The objective of
the model tests described in the certification specification is to establish
the performance of the rotorcraft in terms of its stability in waves. The wave
conditions in which the rotorcraft is to be certified should be selected
according to the desired level of operability (see (a)(2) below).
This will enable
the overall performance of the rotorcraft to be established for inclusion in
the rotorcraft flight manual (RFM) as required by CS 27.1587(b)(3). In the case of
approval with
ditching provisions, the wave conditions selected for substantiation of
behaviour during the water entry phase must also be taken into account.
The rotorcraft
design is to be tested, at each mass condition (see paragraph b(1)(ii) below),
with its flotation system intact, and with its single most critical flotation
compartment damaged (i.e. the single-puncture case which has the worst adverse
effect on flotation stability).
(2) Model test wave
conditions
The rotorcraft is
to be tested in a single sea condition comprising a single combination of
significant wave height (Hs) and zero-crossing period (Tz).
The values of Hs and Tz should be no less than, and no
more than, respectively, those chosen for certification, i.e. as selected from
table 1. This approach is necessary in order to constrain the quantity of
testing required within reasonable limits and is considered to be conservative.
The justification is detailed in Appendix
2.
The applicant is at
liberty to certify the rotorcraft to any significant wave height Hs. This
significant wave height will be noted as performance information in the RFM.
Using reliable wave
climate data for an appropriate region of the ocean for the anticipated flight
operations, a Tz is selected to accompany the Hs. This Tz
should be typical of those occurring at Hs as determined in the
wave scatter table for the region. The mode or median of the Tz
distribution at Hs should be used.
It is considered
that the northern North Sea represents a conservatively ‘hostile’ region of
the ocean worldwide and should be adopted as the default wave climate for
certification. However, this does not preclude an applicant from certifying a
rotorcraft specifically for a different region. Such a certification for a
specific region would require the geographical limits of that certification
region to be noted as performance information in the RFM. Certification for
the default northern North Sea wave climate does not require any geographical
limits.
In the case of an
approval with emergency flotation provisions, operational limitations may
limit flight to ‘non-hostile’ sea areas. For simplicity, the northern North
Sea may still be selected as the wave climate for certification, or
alternatively a wave climate derived from a non-hostile region’s data may be
used. If the latter approach is chosen, and it is desired to avoid
geographical limits, a ‘non-hostile’ default wave climate will need to be
agreed with EASA.
Wave climate data
for the northern North Sea were obtained from the United Kingdom
Meteorological Office (UK Met Office) for a typical ‘hostile’ helicopter
route. The route selected was from Aberdeen to Block 211/27 in the UK sector
of the North Sea. Data tables were derived from a UK Met Office analysis of 34
years of 3-hourly wave data generated within an 8-km, resolved wave model
hindcast for European waters. This data represents the default wave climate.
Table 1 below has
been derived from this data and contains combinations of Hs and Tz.
Table 1 also
includes the probability of exceedance (Pe) of the Hs.
Table 1 — Northern North Sea wave climate
|
|
Spectrum shape: JONSWAP, peak enhancement factor γ
= 3.3 |
|||
|
|
Significant wave height Hs |
Mean wave period Tz |
Significant steepness Ss = 2πHs/(gTz2) |
Hs probability of exceedance Pe |
|
Intact flotation system |
6 m |
7.9 s |
1/16.2 |
1.2 % |
|
5.5 m |
7.6 s |
1/16.4 |
2 % |
|
|
5 m |
7.3 s |
1/16.6 |
3 % |
|
|
4.5 m |
7.0 s |
1/17.0 |
5 % |
|
|
4 m |
6.7 s |
1/17.5 |
8 % |
|
|
3.5 m |
6.3 s |
1/17.7 |
13 % |
|
|
3 m |
5.9 s |
1/18.1 |
20 % |
|
|
2.5 m |
5.5 s |
1/18.9 |
29 % |
|
|
2 m |
5.1 s |
1/20.3 |
43 % |
|
|
1.25 m |
4.4 s |
1/24.2 |
72 % |
|
(3) Target
probability of capsizing
Target probabilities of
capsizing have been derived from a risk assessment. The target probabilities
to be applied are as stated in CS
27.801(e) and 27.802(c), as
applicable.
For ditching, the intact
flotation system probability of capsizing of 3 % is derived from a historic
ditching rate of 3.32 x 10⁻⁶ per flight hour and an AC 27.1309
consequence of hazardous, which implies a frequency of capsizing of less than
10-7 per flight hour. The damaged flotation system probability of
capsizing is increased by a factor of 10 to 30 % on the assumption that the
probability of failure of the critical float compartment is 0.1; this
probability has been estimated, as there is insufficient data on flotation
system failure rates.
For emergency flotation
equipment, an increase of half an order (√10) is allowed on the assumption of
a reduced exposure to the risk, resulting in a probability of capsizing of
10 %. The probability of a capsizing with a damaged flotation system is
consequently increased to 100 %, hence no test is required.
(4) Intact
flotation system
For the case of an intact
flotation system, if the northern North Sea default wave climate has been
chosen for certification, the rotorcraft should be shown to resist capsize in
a sea condition selected from Table 1. The probability of capsizing in a 5-minute
exposure to the selected sea condition is to be demonstrated to be less than
or equal to the appropriate value provided in CS 27.801(e) or 27.802(c), as appropriate,
with a confidence of 95 % or greater.
(5) Damaged
flotation system
For the case of a damaged
flotation compartment (see (1) above), the same sea condition may be used, but
a 10-fold increased probability of capsizing is permitted. This is because it
is assumed that flotation system damage will occur in approximately one out of
ten emergency landings on water. Thus, the probability of capsizing in a
5-minute exposure to the sea condition is to be demonstrated to be less than
or equal to 10 times the required probability for the intact flotation system
case, with a confidence of 95 % or greater. Where a 10-times probability is
equal to or greater than 100 %, it is not necessary to perform a model test to
determine the capsize probability with a damaged flotation system.
Alternatively, the
applicant may select a wave condition with 10 times the probability of
exceedance Pe of the significant wave height (Hs)
selected for the intact flotation condition. In this case, the probability of
capsizing in a 5-minute exposure to the sea condition is to be demonstrated to
be less than or equal to the required value (see CS 27.801(e) or 27.802(c)), with a
confidence of 95 % or greater.
(6) Long-crested
waves
Whilst it is recognised
that ocean waves are in general multidirectional (short-crested), the model
tests are to be performed in unidirectional (long-crested) waves, this being
regarded as a conservative approach to capsize probability.
(b) Procedures
(1) Rotorcraft
model
(i) Construction
and scale of the model
The rotorcraft model, including its emergency flotation, is to be
constructed to be geometrically similar to the full-scale rotorcraft design at
a scale that will permit the required wave conditions to be accurately
represented in the model basin. It is recommended that the scale of the model
should be not smaller than 1/15.
The construction of the model is to be sufficiently light to permit the
model to be ballasted to achieve the desired weight and rotational inertias
specified in the mass conditions (see (b)(1)(ii) below)[3].
Where it is likely that water may flood into the internal spaces
following an emergency landing on water, for example through doors opened to
permit escape, or any other opening, the model should represent these internal
spaces and openings as realistically as possible.
It is permissible to omit the main rotor(s) from the model, but its
(their) mass is to be represented in the mass and inertia conditions[4].
(ii) Mass
conditions
As it is unlikely that the most critical condition can be determined
reliably prior to testing, the model is to be tested in two mass conditions:
(A) maximum
mass condition, mid C of G; and
(B) minimum
mass condition, mid C of G.
(iii) Mass
properties
The model is to be ballasted in order to achieve the required scale
weight, centre of gravity, roll and yaw inertia for each of the mass
conditions to be tested.
Once ballasted, the model’s floating draft and trim in calm water is to
be checked and compared with the design floating attitude.
The required mass properties and floating draft and trim, and those
measured during model preparation, are to be fully documented and compared in
the report.
(iv) Model
restraint system
The primary method of testing is with a restrained model, but an
alternative option is for a free-floating model (See (3)(iii) below).
For the primary restrained method, a flexible restraint or mooring
system is to be provided to restrain the model in order for it to remain
beam-on to the waves in the model basin[5].
This restraint system should fulfil the following criteria:
(A) be
attached to the model on the centre line at the front and rear of the fuselage
in such a position that roll motion coupling is minimised; an attachment at or
near the waterline is preferred; and
(B) be
sufficiently flexible that the natural frequencies of the model
surging/swaying on this restraint system are much lower than the lowest wave
frequencies in the spectrum.
(v) Sea
anchor
Whether or not the rotorcraft is to be fitted with a sea anchor, such
an anchor is not to be represented in these model tests[6].
(2) Test
facility
The model test facility
is to have the capability to generate realistic long non-repeating sequences
of unidirectional (long-crested) irregular waves, as well as the
characteristic wave
condition at the chosen model scale. The facility is to be deep enough to
ensure that the waves are not influenced by the depth (i.e. deep-water waves).
The dimensions of the
test facility are to be sufficiently large to avoid any significant
reflection/refraction effects influencing the behaviour of the rotorcraft
model.
The facility is to be
fitted with a high-quality wave-absorbing system or beach.
The model basin is to
provide full details of the performance of the wave maker and the wave
absorption system prior to testing.
(3) Model
test set-up
(i) General
The model is to be installed in the wave facility in a location
sufficiently distant from the wave maker, tank walls and beach/absorber such
that the wave conditions are repeatable and not influenced by the boundaries.
The model is to be attached to the model restraint system (see
(b)(1)(iv) above).
(ii) Instrumentation
and visual records
During wave calibration tests, three wave elevation probes are to be
installed and their outputs continuously recorded. These probes are to be
installed at the intended model location, a few metres to the side and a few
metres ahead of this location.
The wave probe at the model location is to be removed during tests with
the rotorcraft model present.
All tests are to be continuously recorded on digital video. It is
required that at least two simultaneous views of the model are to be recorded.
One is to be in line with the model axis (i.e. viewing along the wave crests),
and the other is to be a three-quarter view of the model from the up-wave
direction. Video records are to incorporate a time code to facilitate
synchronisation with the wave elevation records in order to permit the
investigation of the circumstances and details of a particular capsize event.
(iii) Wave
conditions and calibration
Prior to the installation of the rotorcraft model in the test facility,
the required wave conditions are to be pre-calibrated.
Wave elevation probes are to be installed at the model location,
alongside and ahead of the intended model location.
The intended wave spectrum is to be run for the full exposure duration
required to demonstrate the required probability of capsizing. The analysis of
these wave calibration runs is to be used to:
(A) confirm
that the required wave spectrum has been obtained at the model location; and
(B) verify
that the wave spectrum does not deteriorate appreciably during the run in
order to help establish the maximum duration test that can be run before the
test facility must be allowed to become calm again.
It should be demonstrated that the wave spectrum measured at each of
the three locations is the same.
If a free-floating model is to be used, then the waves are to be
calibrated for a range of locations down the basin, and the spectrum measured
in each of these locations should be shown to be the same. The length of the
basin covered by this range will be the permitted test region for the
free-floating model, and the model will be recovered when it drifts outside
this region (See Section 4). It should be demonstrated that the time series of
the waves measured at the model location does not repeat during the run.
Furthermore, it should be demonstrated that one or more continuation runs can
be performed using exactly the same wave spectrum and period, but with
different wave time series. This is to permit a long exposure to the wave
conditions to be built up from a number of separate runs without any
unrealistic repetition of the time series.
No wind simulation is to be used[7].
(iv) Required
wave run durations
The total duration of runs required to demonstrate that the required
probability of capsizing has been achieved (or bettered) is dependent on that
probability itself, and on the reliability or confidence of the capsize
probability required to be demonstrated.
With the assumption that each 5-minute exposure to the wave conditions
is independent, the equations provided in (b)(5) below can be used to
determine the duration without a capsize that is required to demonstrate the
required performance.[8]
(See Appendix 1 below for
examples.)
(4) Test
execution and results
Tests are to start with
the model at rest and the wave basin calm.
Following the start of
the wave maker, sufficient time is to elapse to permit the slowest
(highest-frequency) wave components to arrive at the model, before data
recording starts.
Wave runs are to continue
for the maximum permitted duration determined in the wave calibration test, or
in the flee-floating option for as long as the model remains in the calibrated
wave region. Following sufficient time to allow the basin to become calm
again, additional runs are to be conducted until the necessary total exposure
duration (Ttest) has been achieved (see (b)(5) below).
In the case of the
free-floating option, the model may be recovered and relaunched without
stopping the wave maker, provided that the maximum permitted duration is not
exceeded. See paragraph (4)(iv) for requirements regarding relaunching the
free-floating model.
If and when a model
capsize occurs, the time of the capsize from the start of the run is to be
recorded, and the run stopped. The model is to be recovered, drained of any
water, and reset in the basin for a continuation run to be performed.
There are a number of
options that may be taken following a capsize event:
(i) Continuing
with the same model configuration.
If the test is to be continued with the same model configuration, the
test can be restarted with a different wave time series, or continued from the
point of capsizing in a pseudorandom time series.
(ii) Reducing
the wave severity to achieve certification at a lower significant wave height.
Provided that the same basic pseudorandom wave time series can be
reproduced by the wave basin at a lower wave height and corresponding period,
it is permitted to restart the wave maker time series at a point at least 5
minutes prior to the capsize event, and if the model is now seen to survive
the wave sequence that caused a capsize in the more severe condition, then
credit can then be taken for the run duration successfully achieved prior to
the capsize. Clearly, such a restart is only possible with a model basin using
pseudorandom wave generation.
This method is only permitted if the change in significant wave height
and period is sufficiently small that the same sequence of capsizing waves,
albeit at a lower amplitude, can be seen in the wave basin. If this is not the
case, then credit cannot be taken for the exposure time prior to capsize, and
the wave time series must be restarted from the beginning.
(iii) Modifying
the model with the intention of avoiding a capsize.
If it is decided to modify the model flotation with the intention of
demonstrating that the modified model does not capsize in the wave condition,
then the pseudorandom wave maker time series should be restarted at a point at
least 5 minutes prior to the capsize event so that the model is seen to
survive the wave that caused a capsize prior to the modification. Credit can
then be taken for the duration of the run successfully achieved prior to the
capsize.
(iv) Repeating
a restrained capsize event with a free-floating model.
If it is suspected that the model restraint system might have
contributed to the capsize event, it is permitted to repeat that part of the
pseudorandom time series with a free-floating model. The model is to be
temporally restrained with light lines and then released beam-on to the waves
such that the free-floating model is seen to experience the same wave time
series that caused a capsize in exactly the same position in the basin. It is
accepted that it might require several attempts to find the precise model
release time and position to achieve this.
If the free-floating model, having been launched beam-on to the waves,
is seen to yaw into a more beneficial heading once released, and seen to
survive the wave that caused a capsize in the restrained model, then this is
accepted as negating the capsize seen with the restrained model.
The test may then continue with a restrained model as with (i) above.
(v) Special
considerations regarding relaunching a free-floating model into the calibrated
wave region.
If a free-floating model is being used for the tests, then it is
accepted that the model will need to be recovered as it leaves the calibrated
wave region, and then relaunched at the top of that region. It is essential
that this process does not introduce any statistical or other bias into the
behaviour of the model. For example, there might be a natural tendency to wait
for a spell of calmer waves into which to launch the model. This particular
bias is to be avoided by strictly obeying a fixed time delay between recovery
and relaunch.
Any water accumulated inside the model is not to be drained prior to
the relaunch.
If the model has taken up a heading to the waves that is not beam-on,
then it is permissible to relaunch the model at that same heading.
In all the above cases, continuation runs are to be performed until the
total duration of exposure to the wave condition is sufficient to establish
that the 5-minute probability of capsizing has been determined with the required
confidence of 95 %.
(5) Results
analysis
Given that it has been
demonstrated that the wave time series are non-repeating and statistically
random, the results of the tests may be analysed on the assumption that each
5-minute element of the total time series is independent.
If the model rotorcraft
has not capsized during the total duration of the tests, the confidence that
the probability of capsizing within 5 minutes is less than the target value of
Pcapsize(target), as shown below:
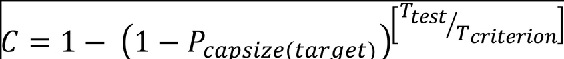
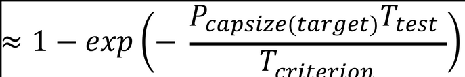
and so the total duration of the model
test required without capsize is provided by:
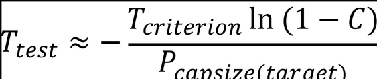
where:
(A) Ttest is the required full-scale
duration of the test (in seconds);
(B) Pcapsize(target) is the required
maximum probability of capsizing within 5 minutes;
(C) Tcriterion is the duration (in
seconds) in which the rotorcraft must meet the no-capsize probability (= 5 x
60 s), as defined in CS 27.801(e); and
(D) C is the required confidence that
the probability of capsizing has been achieved (0.95).
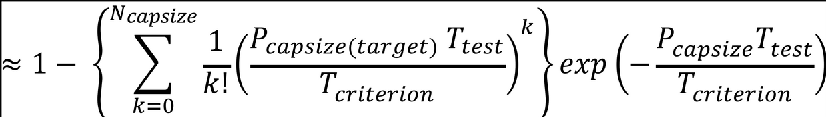
If the rotorcraft has capsized Ncapsize
times during the tests, the probability of capsizing within 5 minutes can
be estimated as:
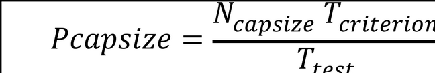
and the
confidence that the required capsize criteria have been met is:
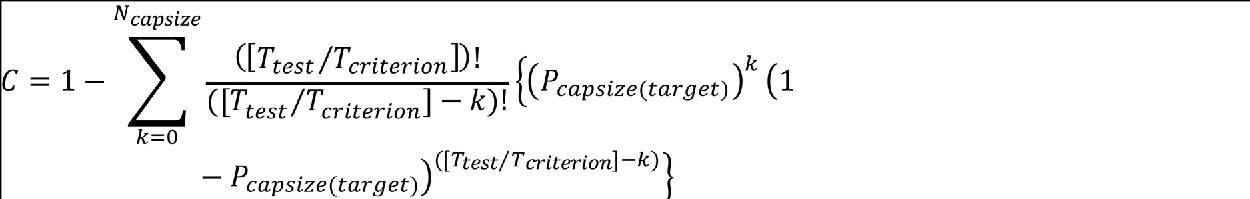
It should be noted that, if the
rotorcraft is permitted to fly over sea conditions with significant wave
heights (Hs) above the certification limit, then Pcapsiz(target) should
be reduced by the probability of exceedance of the certification limit for the
significant wave height (Pe) (see Appendix 2 below).
(c) Deliverables
(1) A comprehensive report describing the
model tests, the facility they were performed in, the model properties, the
wave conditions used, the results of the tests, and the method of analysis to
demonstrate compliance with CS 27.801(d) and (e).
(2) Conclusions in this report are to clarify
the compliance (or otherwise) with those provisions.
(3) Digital video and data records of all
tests performed.
(4) A specification for a certification model
test should also be expected to include:
(i) an execution plan and timescale;
(ii) formal progress reports on content and
frequency; and
(iii) quality assurance requirements.
[Amdt
No: 27/5]
[4] Rotors touching the waves can promote
capsize, but they can also be a stabilising factor depending on the exact
circumstances. Furthermore, rotor blades are often lost during the ditching due
to contact with the sea. It is therefore considered acceptable to omit them
from the model.
[5] In general the model cannot be permitted to
float freely in the basin because in the necessarily long-wave test durations,
the model would otherwise drift down the basin and out of the calibrated wave
region. Constraining the model to remain beam-on to the waves and not float
freely is regarded as a conservative approach to the capsize test. A
free-floating test is optional after a specific capsize event, in order to
investigate whether the restraint system contributed to the event. It may also
be possible to perform a complete free-floating test campaign by combining many
short exposures in a wave basin capable of demonstrating a large calibrated
wave region.
[7] Wind generally has a tendency to redirect
the rotorcraft nose into the wind/waves, thus reducing the likelihood of
capsize. Therefore, this conservative testing approach does not include a wind
simulation.
[8] Each 5-minute exposure might not be
independent if, for example, there was flooding of the rotorcraft,
progressively degrading its stability. However, in this context, it is
considered that the assumption of independence is conservative.